# OGLO Tactile Glove Plugin
C++ plugin that streams **OGLO** tactile gloves over BLE into the standard
DeviceIO recording path. Each glove (one BLE device per hand) provides **80
tactile taxels** (5 fingers × 4×4) plus a **6-axis IMU** at 100 Hz. Source and
plugin README: [src/plugins/oglo_tactile/README.md](https://github.com/NVIDIA/IsaacCapture/blob/main/src/plugins/oglo_tactile/README.md).
This plugin follows the [Add a New Device](../add_device.md) pattern (FlatBuffer schema → plugin
`SchemaPusher` → tracker → MCAP) and is modeled on the OAK camera plugin.
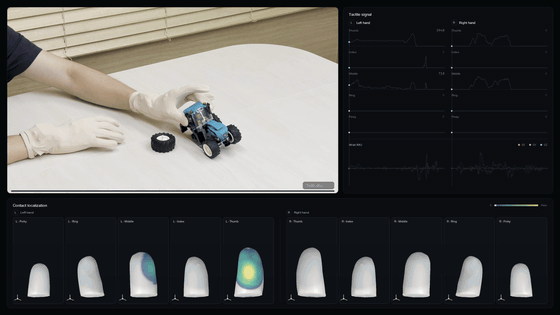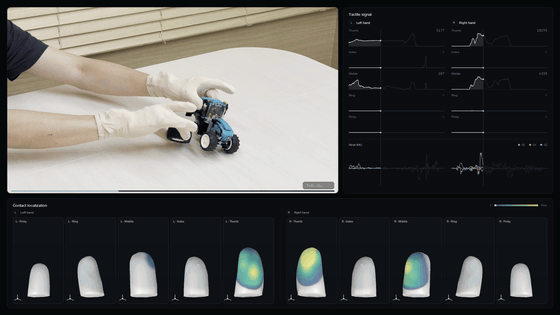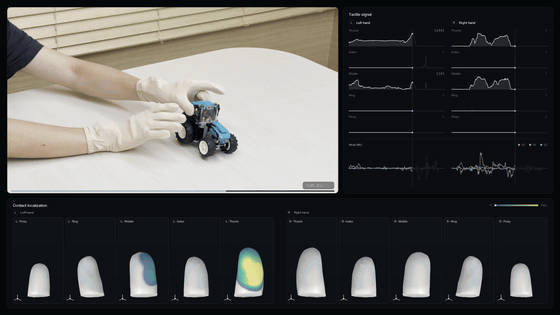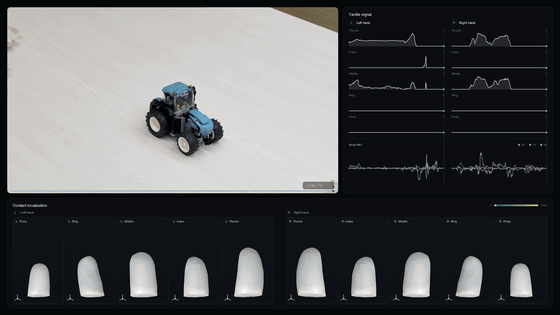
Both OGLO gloves driving a live per-finger contact heatmap while manipulating
an object — 80 taxels + a 6-axis IMU per hand, streamed over BLE at 100 Hz and
time-synced with the operator’s hand/head tracking.
> ##### On this page
>
> * [Components](#components)
> * [Build](#build)
> * [Usage](#usage)
> * [Recorded data](#recorded-data)
> * [IMU frame](#imu-frame)
> * [Tests](#tests)
## Components
- **Schema** — [src/core/schema/fbs/oglo_tactile.fbs](https://github.com/NVIDIA/IsaacCapture/blob/main/src/core/schema/fbs/oglo_tactile.fbs)
(`OgloGloveSample` / `OgloGloveSampleRecord`).
- **Plugin** — [src/plugins/oglo_tactile](https://github.com/NVIDIA/IsaacCapture/tree/main/src/plugins/oglo_tactile) (BLE read → parse → OpenXR push).
- **Tracker** — `OgloTactileTracker`, with live backend
`LiveOgloTactileTrackerImpl`. Both are generated at configure time from the
`oglo_tactile` entry in
[src/core/deviceio_trackers/trackers.toml](https://github.com/NVIDIA/IsaacCapture/blob/main/src/core/deviceio_trackers/trackers.toml).
## Build
Linux only (BlueZ). The plugin is off by default. Complete the
[source-build prerequisites](../../development/build_from_source/index.md) first, then:
```bash
sudo apt install libdbus-1-dev # BlueZ daemon + libdbus for the BLE backend
cmake -B build -DBUILD_PLUGIN_OGLO=ON
cmake --build build --target oglo_tactile_plugin --parallel
```
`nlohmann/json` (MIT) is fetched automatically.
#### NOTE
**BLE backend.** The plugin talks to BlueZ directly over [libdbus](https://www.freedesktop.org/wiki/Software/dbus/) (AFL-2.1, permissive), so
the build carries **no copyleft dependency** and works out of the box. The
transport is isolated behind the `OgloBleClient` interface
([src/plugins/oglo_tactile/ble/oglo_ble_client.hpp](https://github.com/NVIDIA/IsaacCapture/blob/main/src/plugins/oglo_tactile/ble/oglo_ble_client.hpp)), so an
alternative backend can be dropped in via `make_ble_client()` without
touching the parser, schema, or tracker.
## Usage
The plugin streams one glove (`--side`) and pushes it via OpenXR for a host
`OgloTactileTracker` to record:
```bash
# Push for a host OgloTactileTracker into a shared session MCAP
./build/src/plugins/oglo_tactile/oglo_tactile_plugin --side right --collection-prefix=oglo
```
The packet parser reads the device **Config characteristic** first and branches
on the notify `flags` byte (`0x04` packed12 v5 — primary; `0x02`/`0x01`
legacy schema-4 fallback), so payload sizes are never hardcoded.
## Recorded data
The host `OgloTactileTracker` records per hand into channels
`oglo_/oglo` and `oglo_/oglo_tracked`, carrying
`core.OgloGloveSampleRecord`: `seq`, `device_time_us`, `taxels[80]` (raw
12-bit, `finger,row,col`), and a 6-axis IMU, each with a `DeviceDataTimestamp`
whose `sample_time_local_common_clock` is on the shared host monotonic clock —
so OGLO aligns in time with hand/head streams.
**Naming.** The glove’s identity threads through several layers, but all of them
derive from the single `--collection-prefix` you pick (`oglo` below), with the
hand side appended. For the **left** hand:
| Layer | Where it is set | Value (left hand) |
|--------------------------|-------------------------------------------------------------------------------------------------------------------------------|--------------------------------------------|
| CLI flag | `oglo_tactile_plugin --collection-prefix` | `oglo` |
| OpenXR collection id | `OgloTactileTracker("/left")` | `oglo/left` |
| MCAP recording base name | `McapRecordingConfig` tracker name | `oglo_left` |
| MCAP channels | `OgloRecordingTraits` (`oglo`, `oglo_tracked`) | `oglo_left/oglo`, `oglo_left/oglo_tracked` |
| Plugin device path | [src/plugins/oglo_tactile/plugin.yaml](https://github.com/NVIDIA/IsaacCapture/blob/main/src/plugins/oglo_tactile/plugin.yaml) | `/glove/oglo_left` |
The right hand mirrors this (`right` / `oglo_right`), so `mcap info` on a
recording shows `oglo_left/oglo` (+ `_tracked`) and `oglo_right/oglo`
(+ `_tracked`).
A complete data-collection demo (MetaQuest hand/head + both gloves + a live
in-headset tactile heatmap) lives at
[examples/oglo_tactile](https://github.com/NVIDIA/IsaacCapture/tree/main/examples/oglo_tactile); see its `README.md`.
## IMU frame
Each sample includes a 6-axis IMU reading — a 3-axis accelerometer and 3-axis
gyroscope — as raw `int16` sensor counts. Scale: accel ±8 g
(`≈0.000244 g/LSB`), gyro ±2000 dps (`≈0.061 dps/LSB`). The IMU is
wrist-mounted, so its axes form a single **wrist-fixed frame** — they track the
wrist, not individual fingers, and are the sensor’s own raw axes (not aligned to
an anatomical hand frame). For absolute orientation, apply the IMU-to-hand
extrinsic supplied with the hardware, or calibrate against gravity for just “up”.
## Tests
`test_oglo_packet_parser` validates the wire decode against the firmware’s own
12-bit packing reference, plus the schema-4 fallback and malformed-packet
rejection:
The plugin target above does not build the test, so build it first:
```bash
cmake --build build --target test_oglo_packet_parser --parallel
ctest --test-dir build -R oglo_packet_parser --output-on-failure
```