# LeRobot and SO-101
With Isaac Teleop, we got an end-to-end data collection and training pipeline for SO-101 in both sim and real teleoperation.
The [SO-101](https://github.com/TheRobotStudio/SO-ARM100) is a low-cost, open-source robot arm
that has become a popular platform in the [LeRobot](https://github.com/huggingface/lerobot)
community. Isaac Teleop lets you drive an SO-101 from more than one teleoperation device to collect
demonstrations — in simulation with [Isaac Lab](https://isaac-sim.github.io/IsaacLab) and on real
hardware with [SO-101 support in LeRobot](https://huggingface.co/docs/lerobot/en/so101) — then train a GR00T N1.7
manipulation policy on the result and close the loop from sim to real.
The same SO-101 task runs in Isaac Lab and on the real arm, each recording a LeRobot dataset. The two
panels below stack on narrow screens and sit side by side on wider ones, and can be replaced
independently:
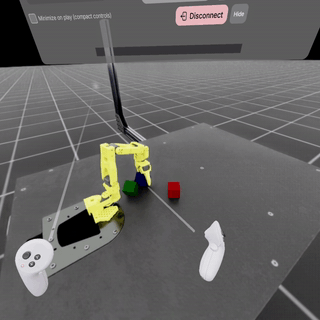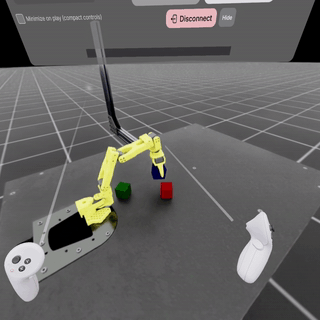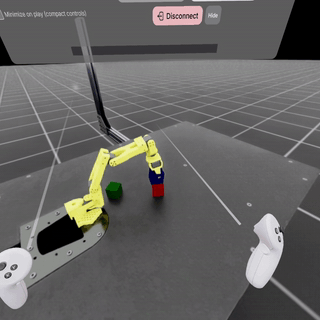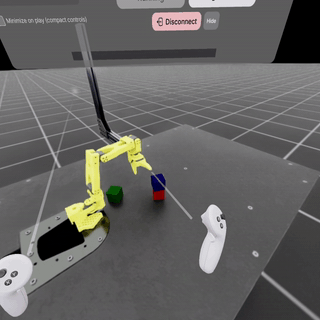
In Isaac Lab (simulation)
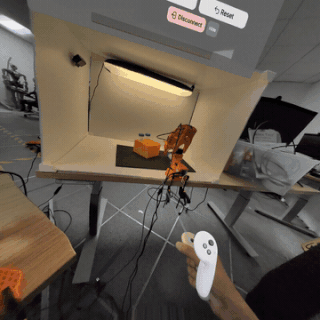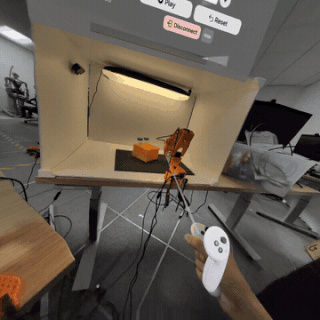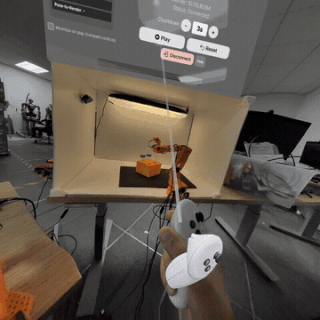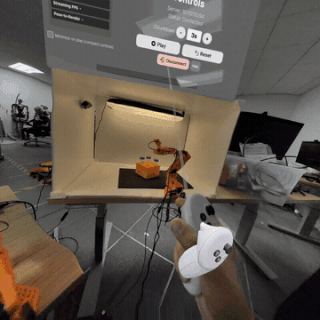
On the real arm
## End-to-end workflow
The same SO-101 embodiment runs in simulation and on real hardware, so a single workflow carries
you from teleoperation to a deployed policy:
1. **Teleoperate and collect.** Drive the SO-101 with the [XR controller or the SO-101 Leader](devices.md) and record demonstrations — in [real](data_collection_real.md) and in
[simulation](data_collection_sim.md). Both produce datasets in the LeRobot format.
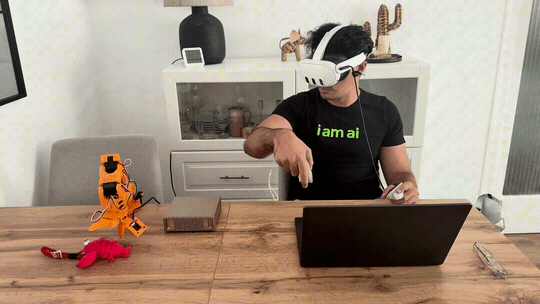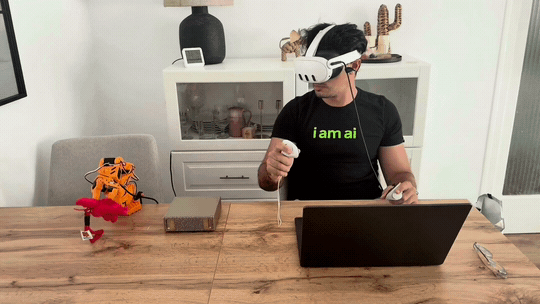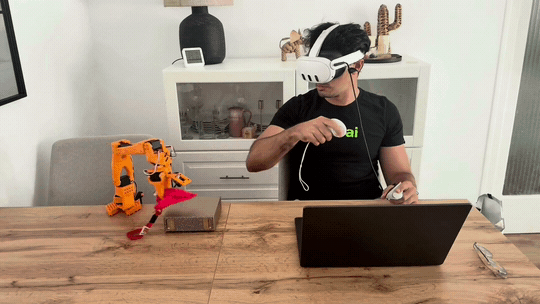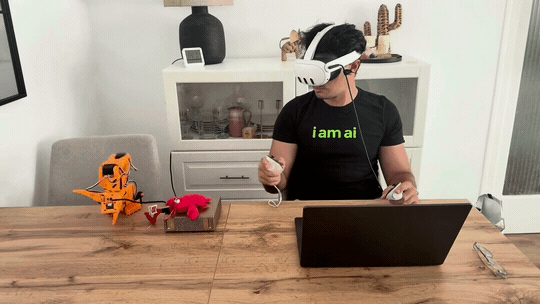
Teleoperation and data collection with LeRobot.
2. **Train.** Fine-tune a [GR00T N1.7](training_groot.md) policy on the collected dataset.
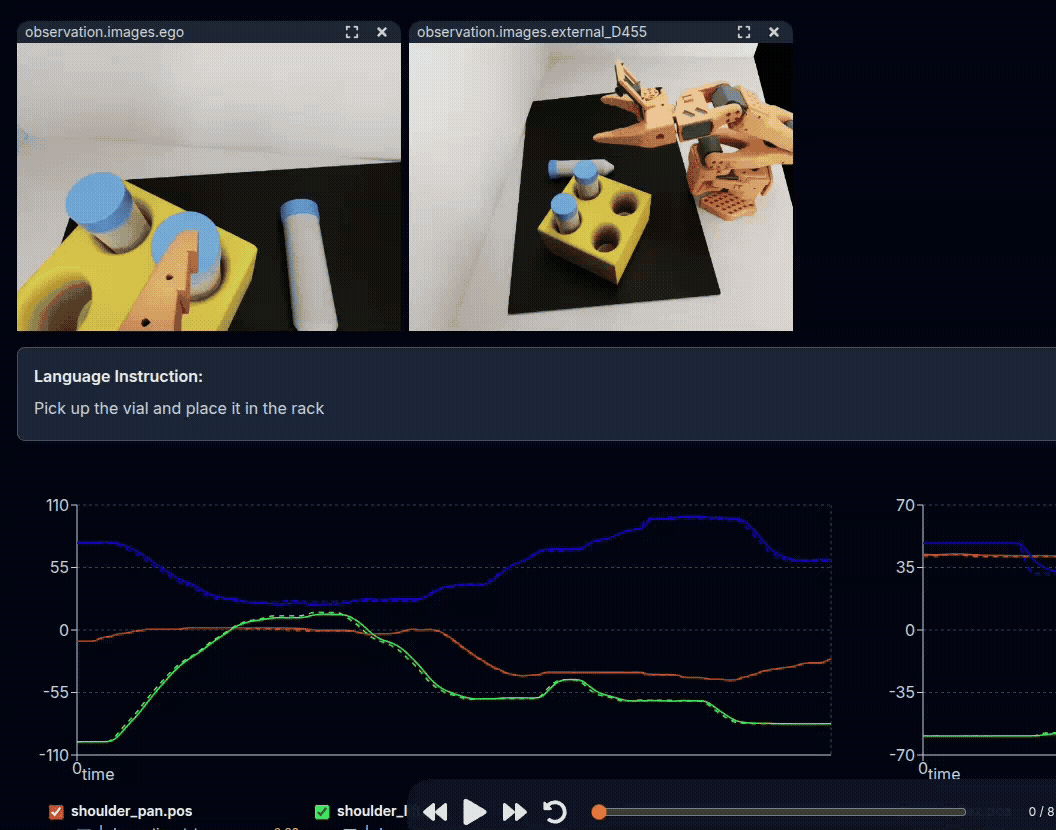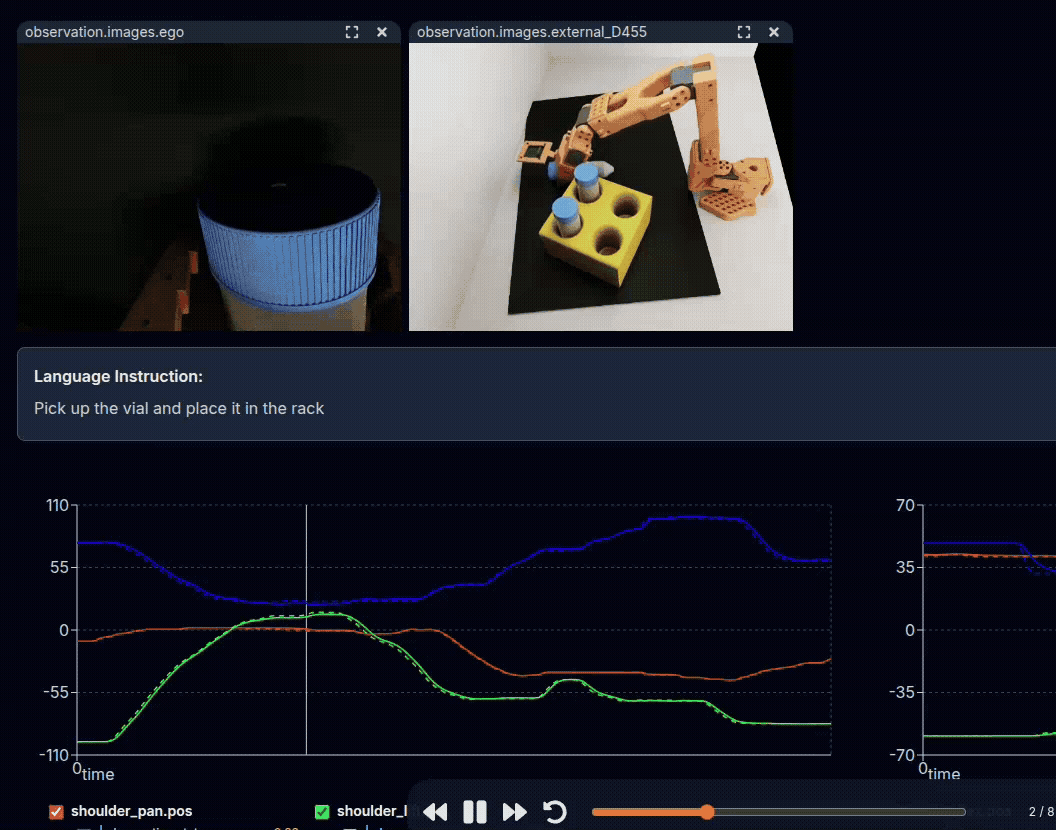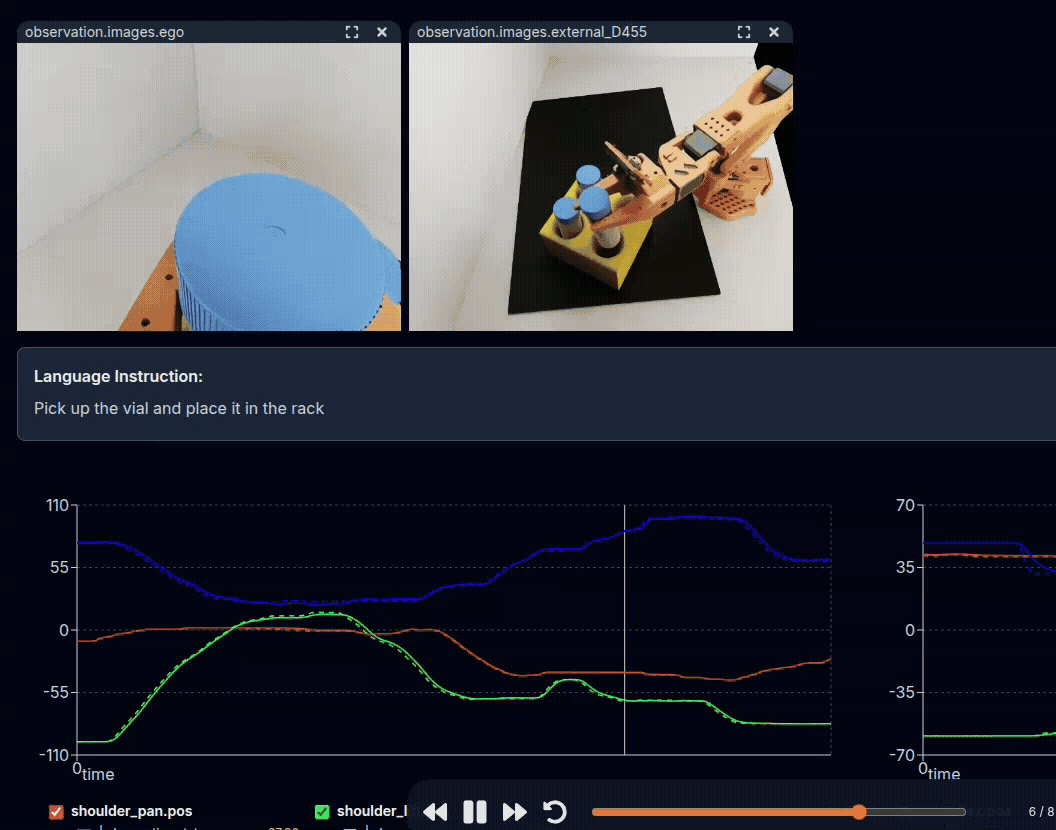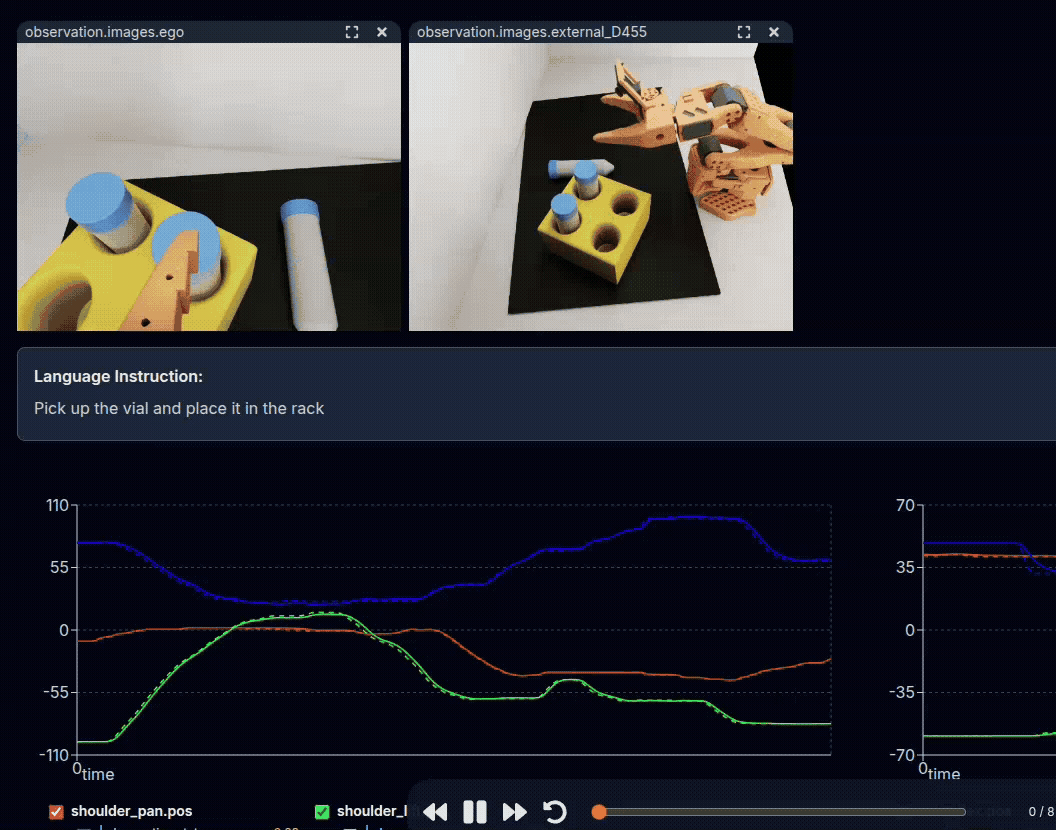
Data set preview with LeRobot.
3. **Deploy.** Take the policy from sim to real — see the [Sim-to-Real SO-101 learning path](https://docs.nvidia.com/learning/physical-ai/sim-to-real-so-101/latest/index.html) —
addressing the sim-to-real gap with domain randomization, sim/real co-training, and
actuator-gap compensation.
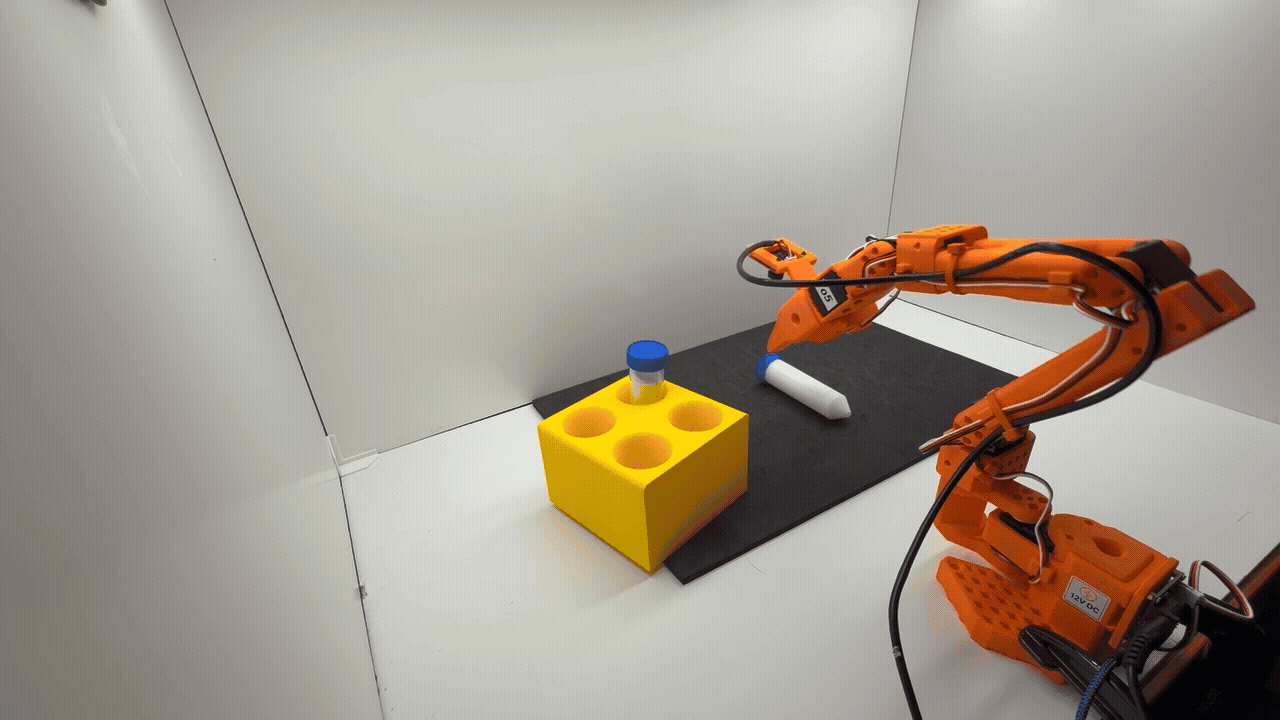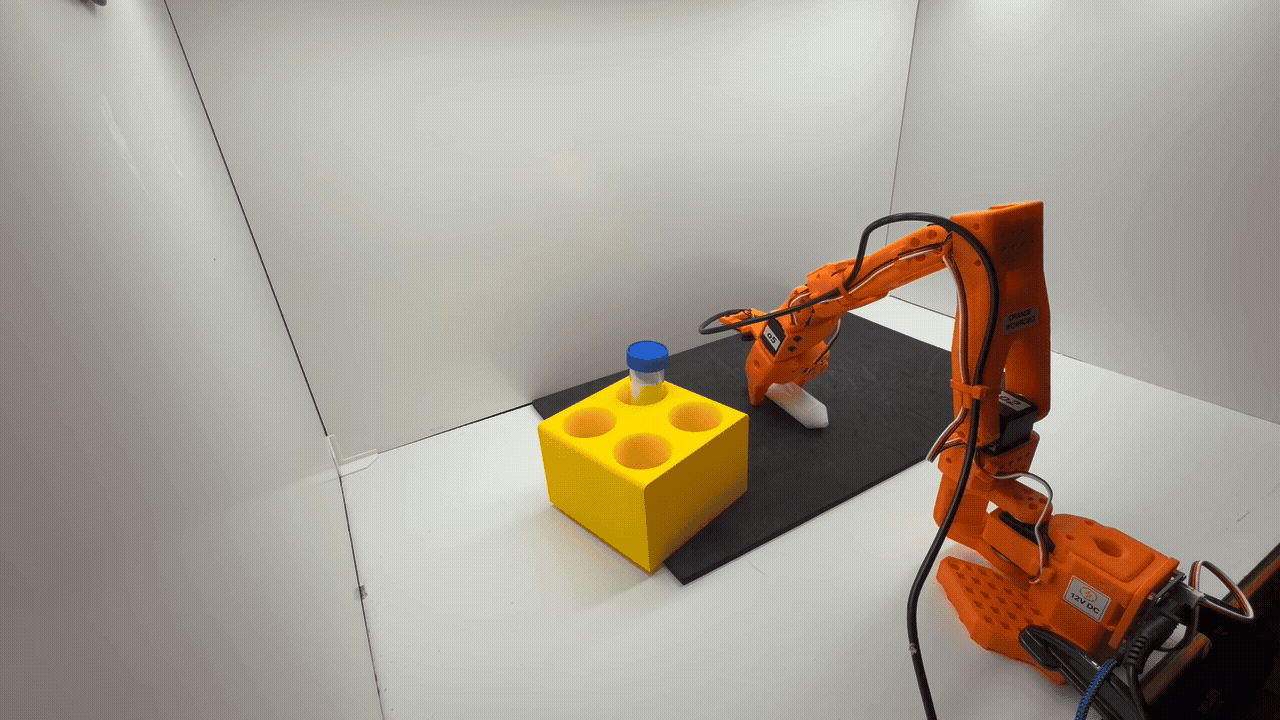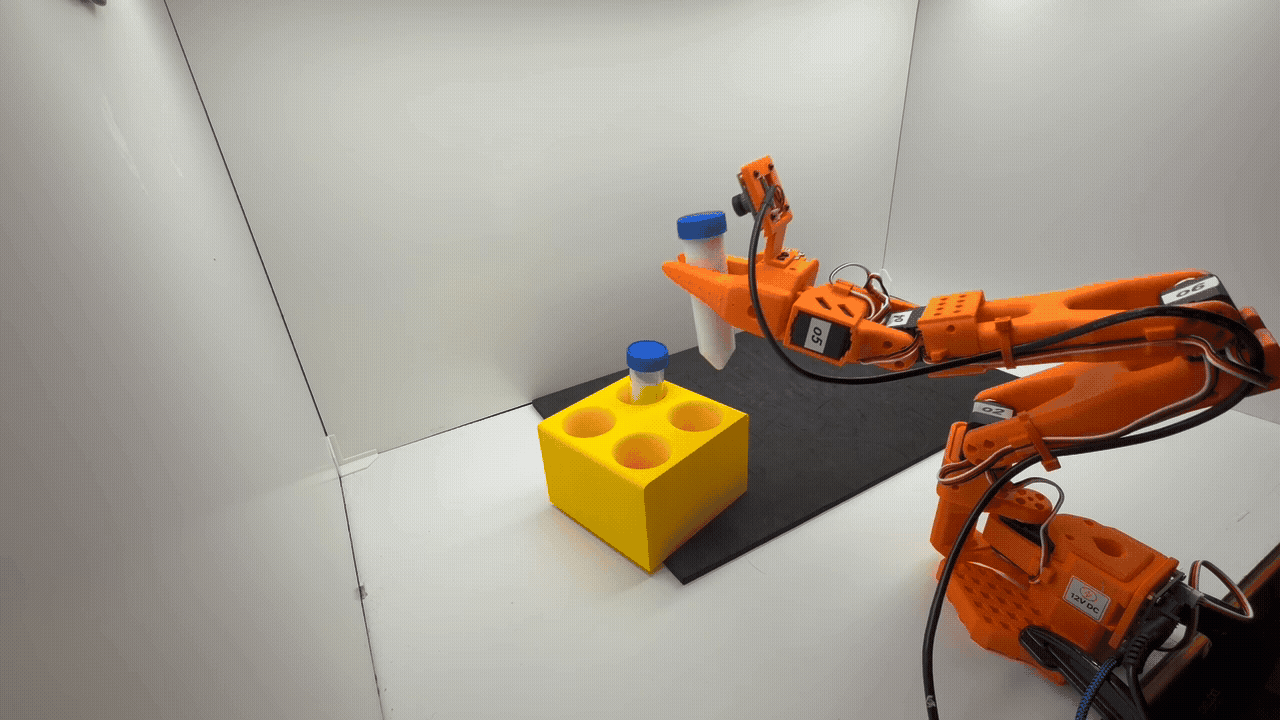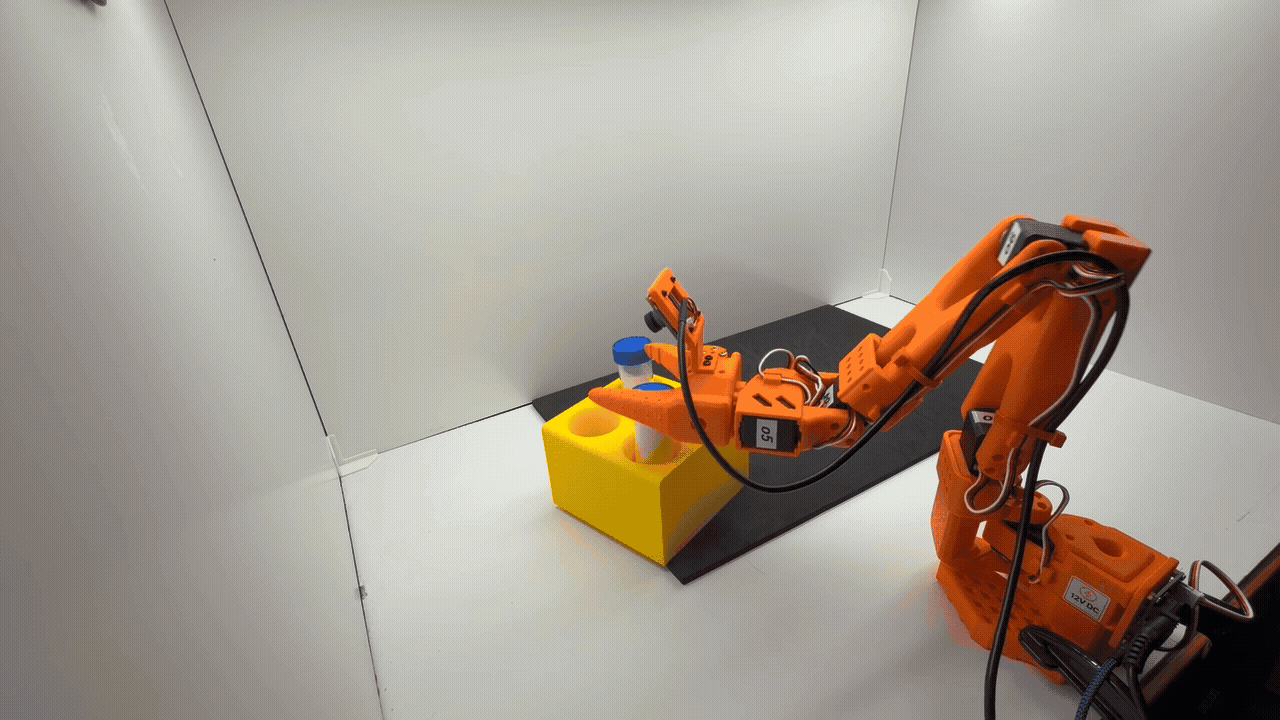
The trained GR00T N1.7 policy running autonomously on the SO-101.
## In this section
- [Supported Teleop devices](devices.md) — the supported teleop devices: the XR controller and the SO-101 Leader.
- [Data Collection in Real](data_collection_real.md) — record demonstrations on a physical SO-101.
- [Data Collection in Sim](data_collection_sim.md) — record demonstrations in Isaac Lab.
- [Model Training with GR00T](training_groot.md) — fine-tune a GR00T N1.7 policy on the collected data.
- [reBot B601-RS on Jetson AGX Orin](rebot.md) — bring up a reBot B601-RS arm on a Jetson AGX Orin over built-in CAN.
New to XR teleoperation? Start with the [Isaac Teleop Quick Start](../../teleop/quick_start.md)
to set up CloudXR and connect a headset.
## Pending Tasks
The guides below are still being written:
☑ Implement teleop devices: XR controller and SO-101 Leader
☑ Data collection in real
☑ Data collection in sim (XR controller)
☑ Data collection in sim (SO-101 Leader)
☐ Export sim demos to the LeRobot dataset format
☐ Model training with GR00T N1.7
☐ Sim-to-Real — update the [Sim-to-Real SO-101 learning path](https://docs.nvidia.com/learning/physical-ai/sim-to-real-so-101/latest/index.html) to use Isaac Teleop
See also: the [Sim-to-Real SO-101 learning path](https://docs.nvidia.com/learning/physical-ai/sim-to-real-so-101/latest/index.html).