

Isaac Teleop#
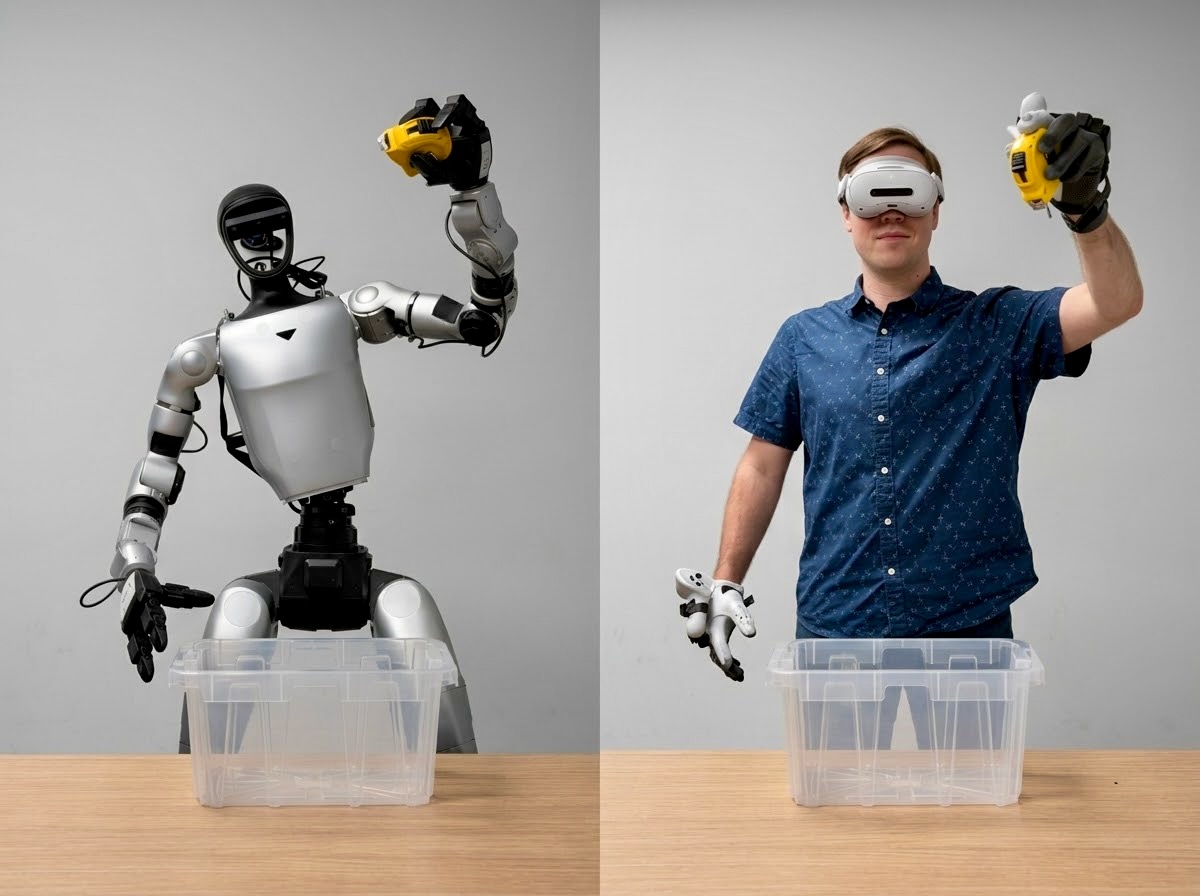
Isaac Teleop is the teleoperation component of Isaac Capture. It combines a standardized device interface, a graph-based retargeting pipeline, and a data collection workflow for simulated and real-world robots.
Key features:
Unified teleoperation workflows for simulation and real robots, including ROS 2 and Isaac Lab integrations.
Standardized device interfaces for XR headsets, gloves, pedals, and body trackers, backed by Isaac Capture’s shared device plugins.
Flexible retargeting to different robot embodiments.
Session management for device tracking, retargeting, and robot control.
Visualization with Televiz for streaming robot camera and sensor feeds, plus 3D reconstruction content, to XR headsets.
Recording and replay of tracking data for repeatable sessions and dataset collection.
Start with Quick Start, then use Teleop Session and Teleop Control State Machine to integrate your application. The LeRobot and SO-101 guides cover SO-101 data collection and training.
Isaac Teleop uses Isaac Capture’s Spatial Trackers and Device Data, Retargeting Interface, and MCAP Recording & Replay. See Architecture for how these shared capabilities relate to the Ego Pipeline.